Design records / FB-001
DWG NO. FB-001
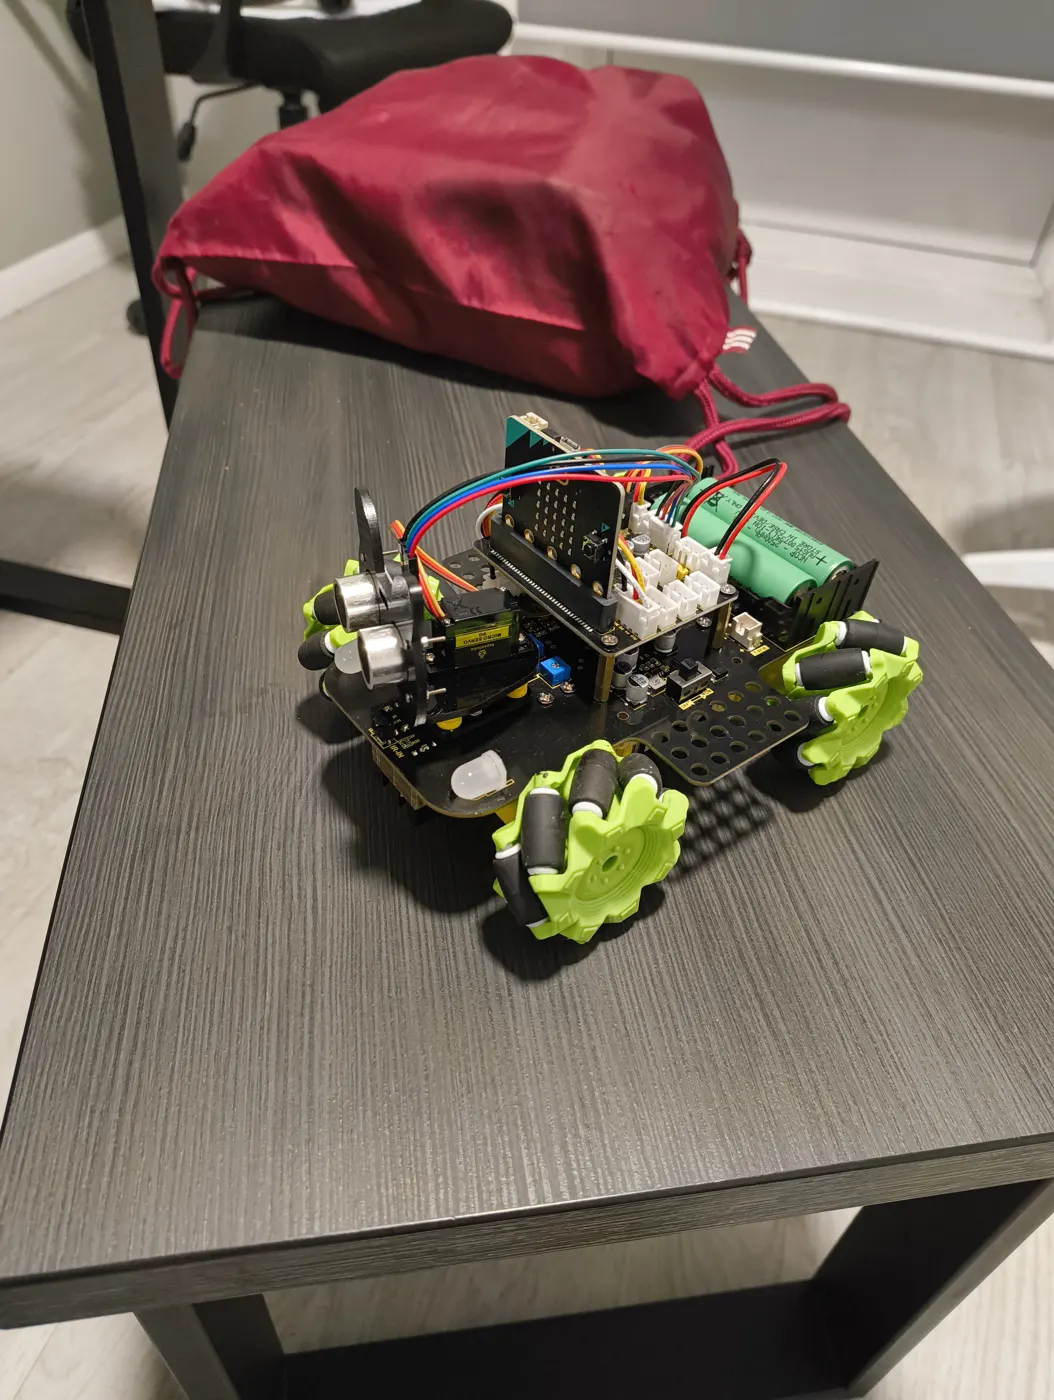
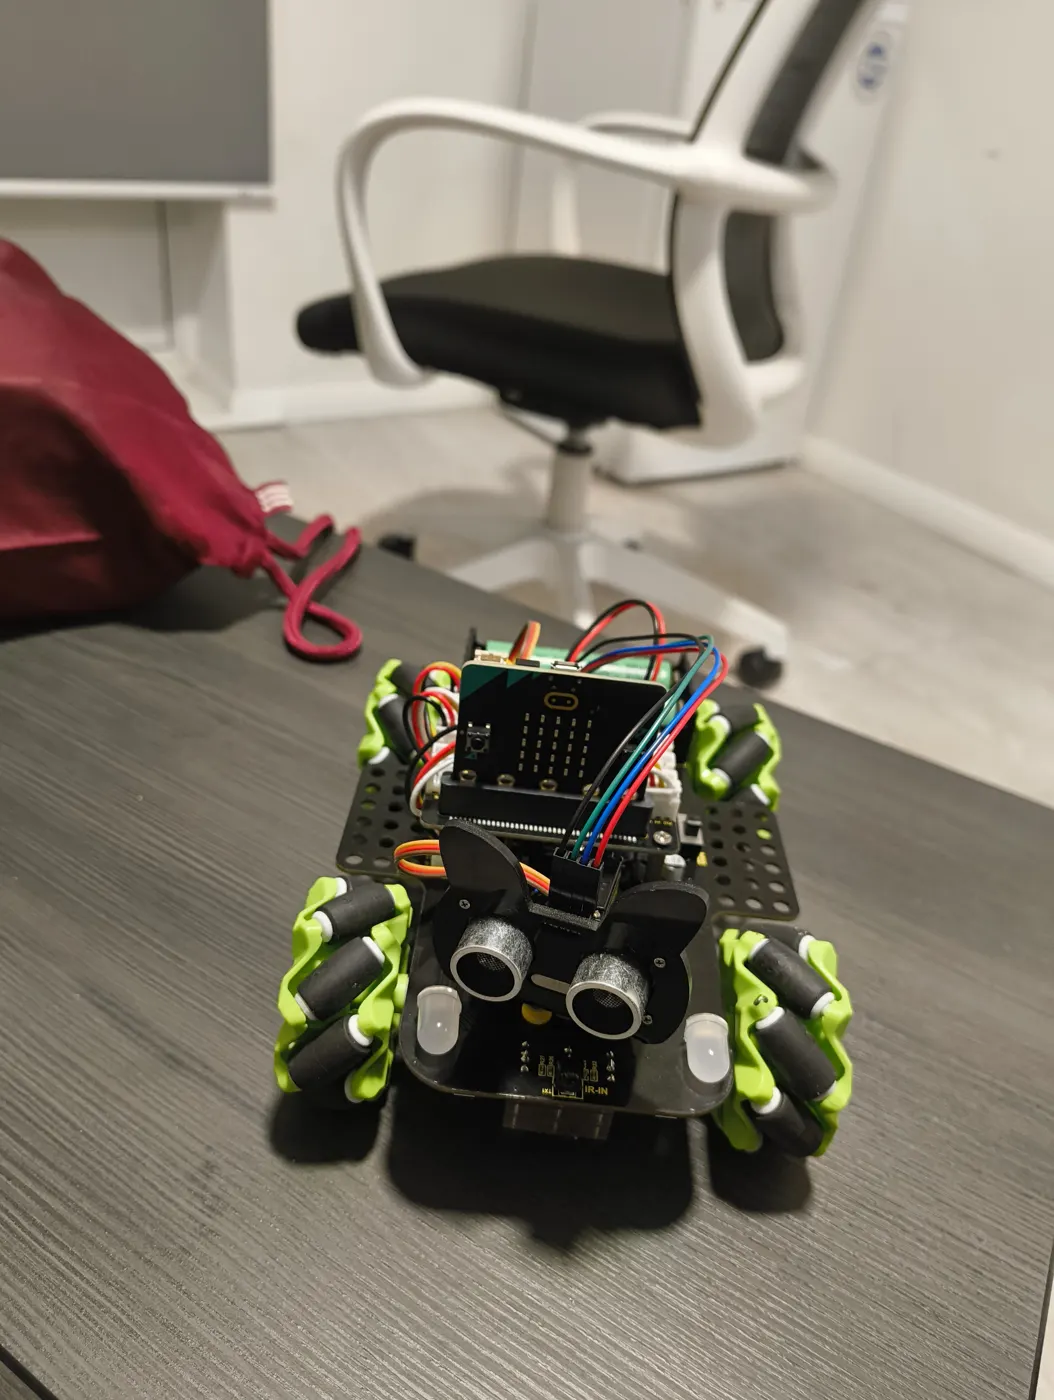
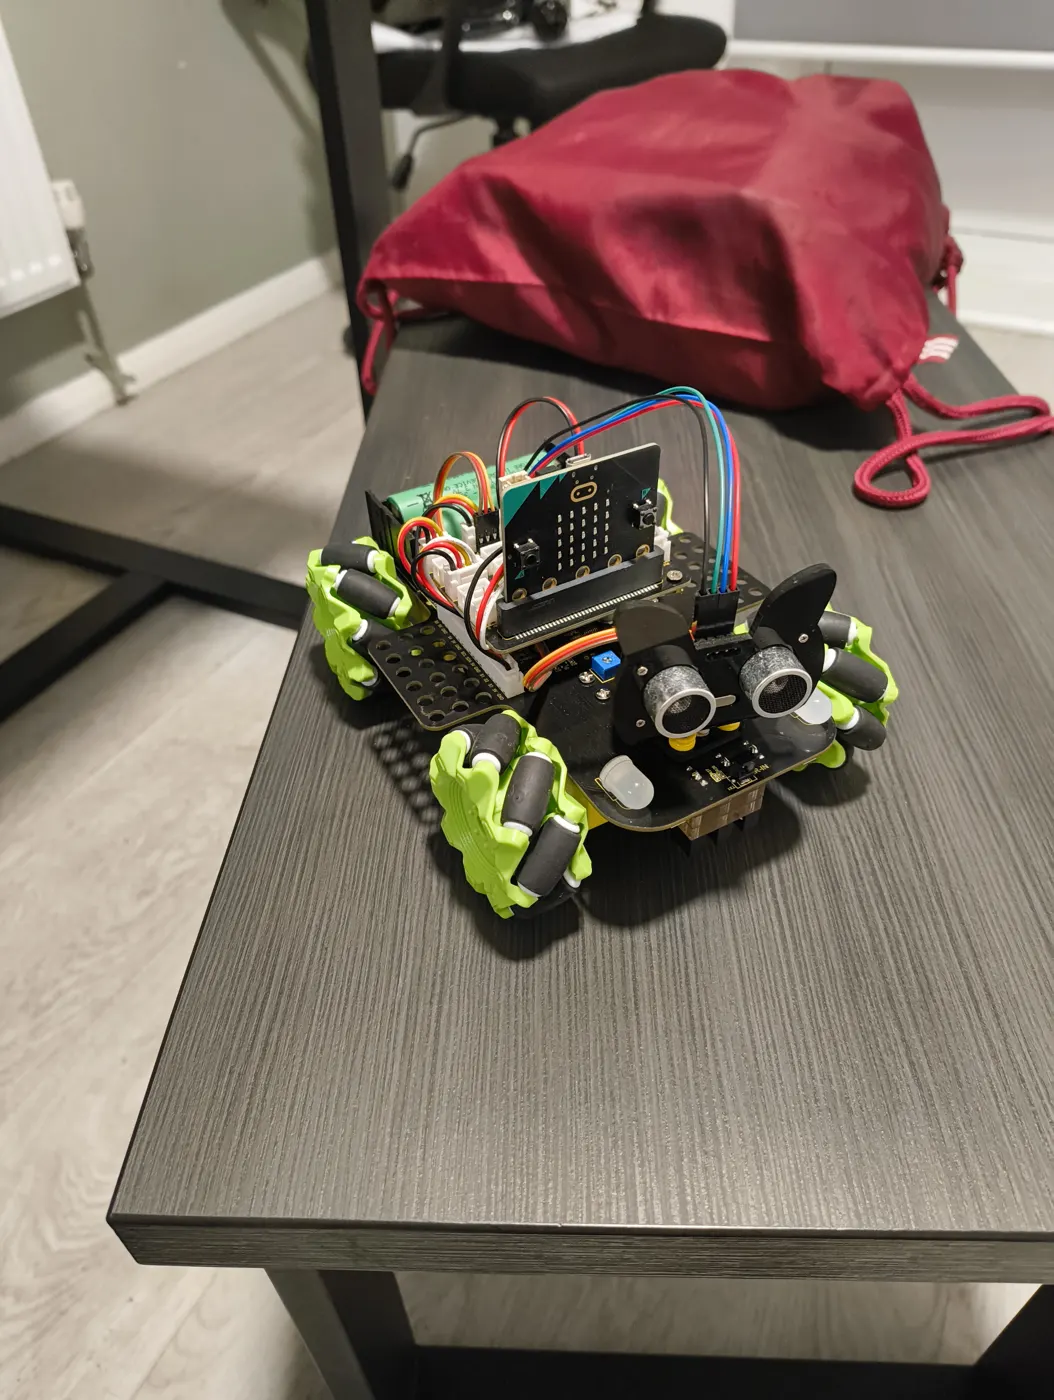
Mecanum line-following car
Omni-directional vehicle on a BBC micro:bit, with mecanum wheels, that followed a drawn course on its own.
The brief
My BEng dissertation researched mecanum wheels against omni-wheels. This mecanum-wheel vehicle was its test platform: a car that can follow a course without human input and move in any direction without turning first.
What I did
- Ordered and assembled a mecanum-wheel robot kit with a BBC micro:bit controller, a driver board, line sensors, an ultrasonic range finder and a two-cell battery pack.
- Wrote my own control code, then used the kit's original code for the final tests, because the dissertation focused on researching the wheel types rather than software.
- Tested it on a hand-drawn course on the floor.
Result
The car followed the full drawn course by itself, including the tight hairpins. The video below is an unedited run using the kit's original code.